Xinwei Ju
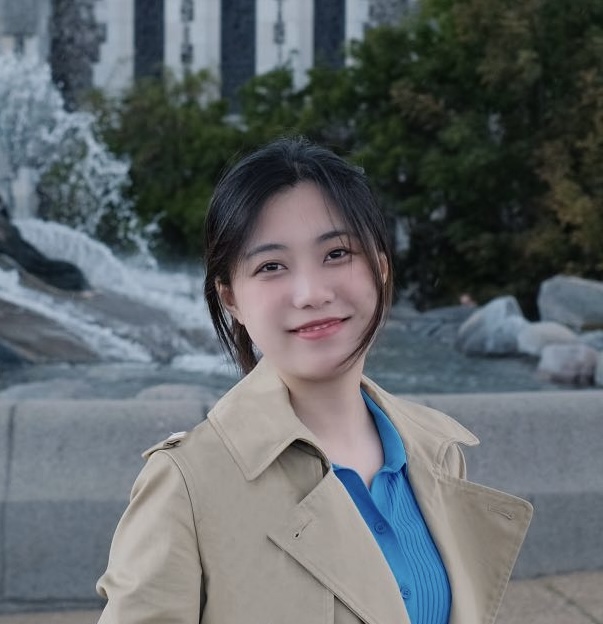
Portrait of Xinwei Ju

Xinwei Ju

PhD Candidate in Computer Science, University College London

My research focuses on computer vision and surgical navigation, particularly depth and pose estimation, semantic understanding, and deformable 3D reconstruction for endoscopic navigation. I am supervised by Dr. Francisco Vasconcelos and Dr. Sophia Bano.

I am open to internship and full-time opportunities in computer vision, 3D reconstruction, SLAM, and image-guided surgical navigation.

Computer VisionSurgical Navigation3D Reconstruction

Selected publications

View all on Google Scholar ↗
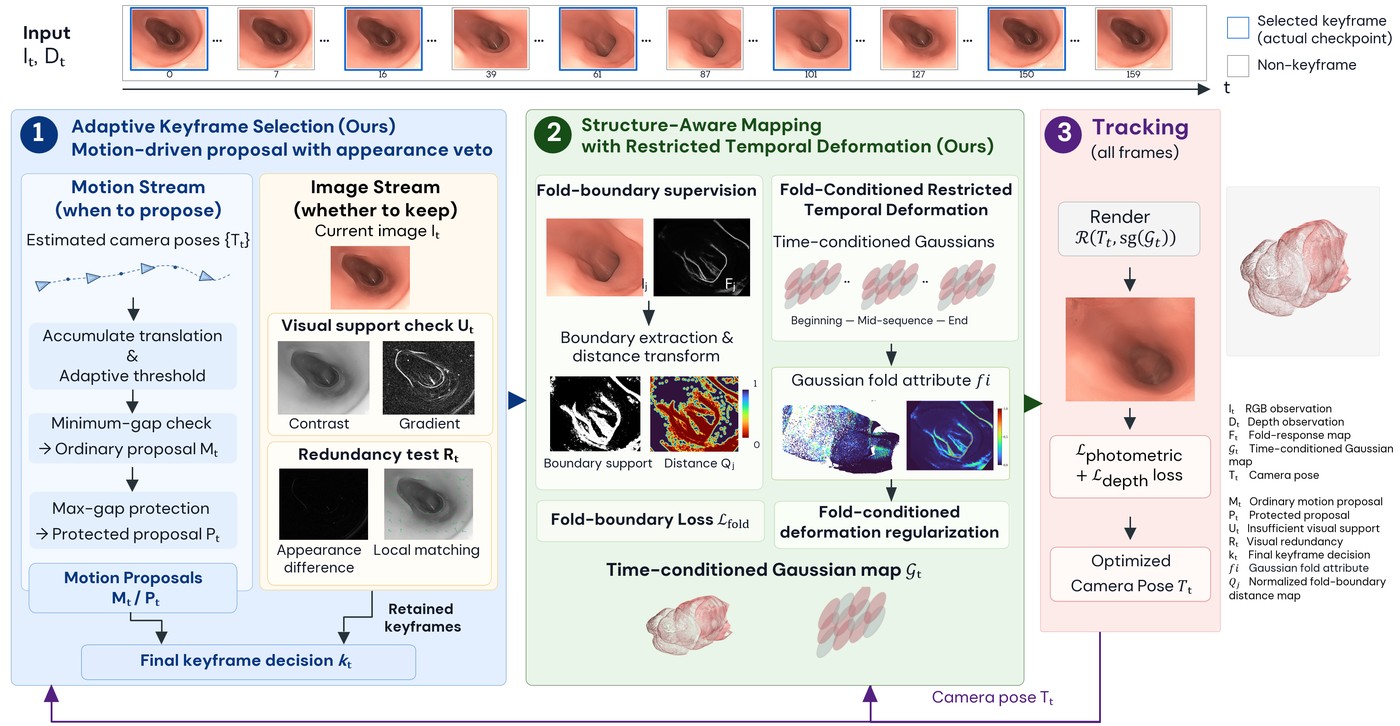
KFS4LAM method pipeline

KFS⁴LAM: Adaptive KeyFrame Selection with Structure-Aware Mapping for Endoscopic Gaussian Splatting SLAM

Xinwei Ju, Zhehua Mao, Tianyi Song, Danail Stoyanov, Sophia Bano, and Francisco Vasconcelos

Paper under review

Colonoscopy video understanding and reconstruction through adaptive keyframe selection and structure-aware Gaussian mapping, retaining informative observations while explicitly modelling fold boundaries and temporal deformation.
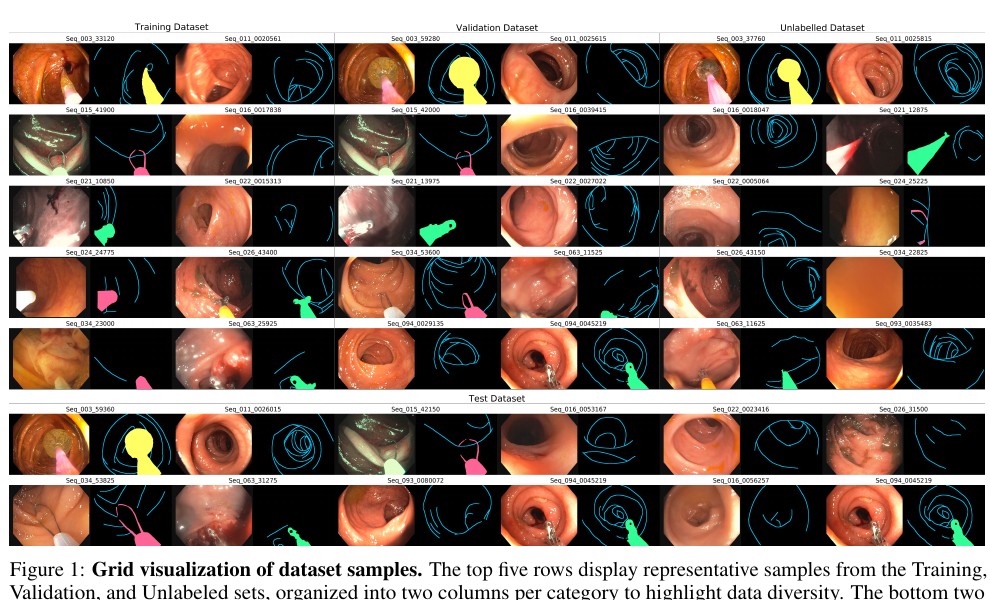
SegCol dataset examples and semantic annotations

SegCol Challenge: Semantic Segmentation for Tools and Fold Edges in Colonoscopy Data

Xinwei Ju*, Rema Daher*, Razvan Caramalau, Baoru Huang, Danail Stoyanov, Francisco Vasconcelos

MICCAI EndoVis Challenge, 2024

The first colonoscopy dataset with detailed pixel-level annotations of colon fold edges and three surgical tool classes, together with benchmarks for segmentation, classification, and annotation-efficient learning.

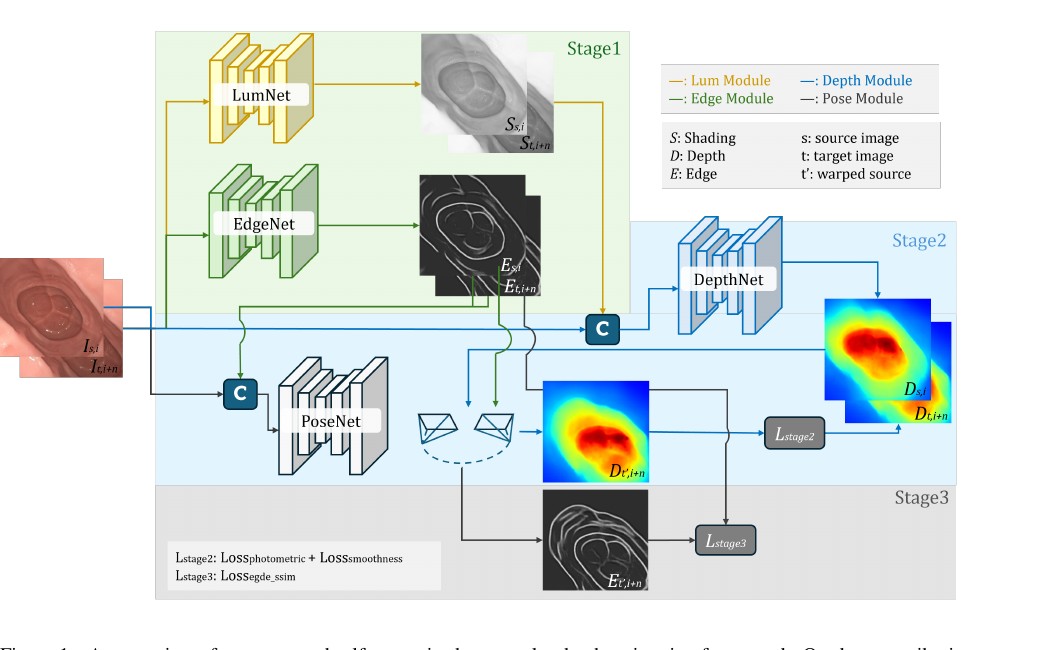
PRISM self-supervised depth and pose estimation framework

Multi-Modal Monocular Endoscopic Depth and Pose Estimation with Edge-Guided Self-Supervision

Xinwei Ju, Rema Daher, Danail Stoyanov, Sophia Bano, Francisco Vasconcelos

International Journal of Computer Assisted Radiology and Surgery, 2026

Introduces strong structural and illumination cues for geometry learning in the low-texture colon: intrinsic shading guides depth, while explicit fold-edge features improve self-supervised camera pose estimation.

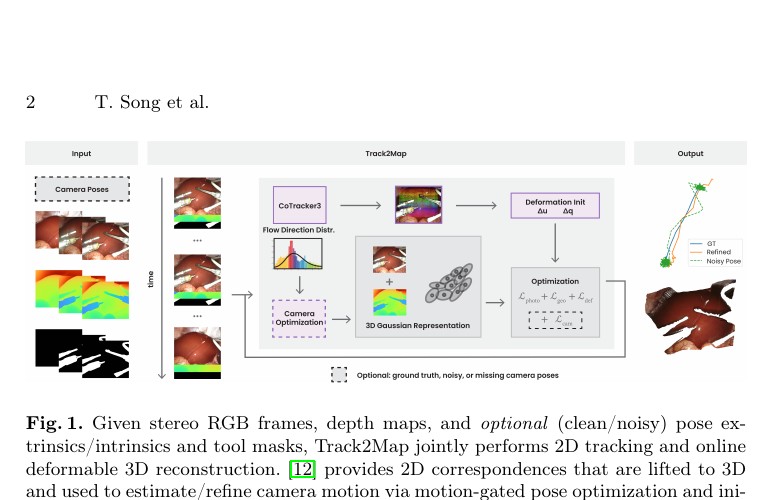
Track2Map method overview

Track2Map: Online Deformable SLAM with Motion-Aware Pose Optimization in Robotic Surgery

Tianyi Song, Sierra Bonilla, Xinwei Ju, et al.

MICCAI, 2026

Jointly estimates camera motion and deformable anatomy online by anchoring 3D Gaussian Splatting to dense 2D tracks and using motion-aware pose optimization to reduce drift.

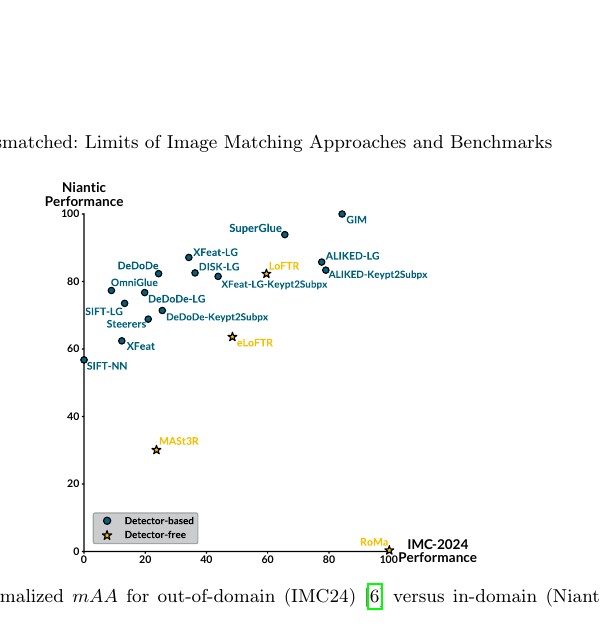
Mismatched benchmark comparison chart

Mismatched: Evaluating the Limits of Image Matching Approaches and Benchmarks

Sierra Bonilla*, Chiara Di Vece*, Rema Daher*, Xinwei Ju*, et al.

ECCV Workshop, 2024

Reveals where standard image-matching benchmarks diverge from downstream structure-from-motion performance, including under domain shift and edge-based preprocessing.

* Equal contribution