Overview
Qualitative - Videos
Trajectory legends report mean ATE in millimeters after Sim3 alignment. Video rendering metrics are averaged over the exact displayed frames at 675 × 540, using a shared depth-unit convention.
Qualitative - Images
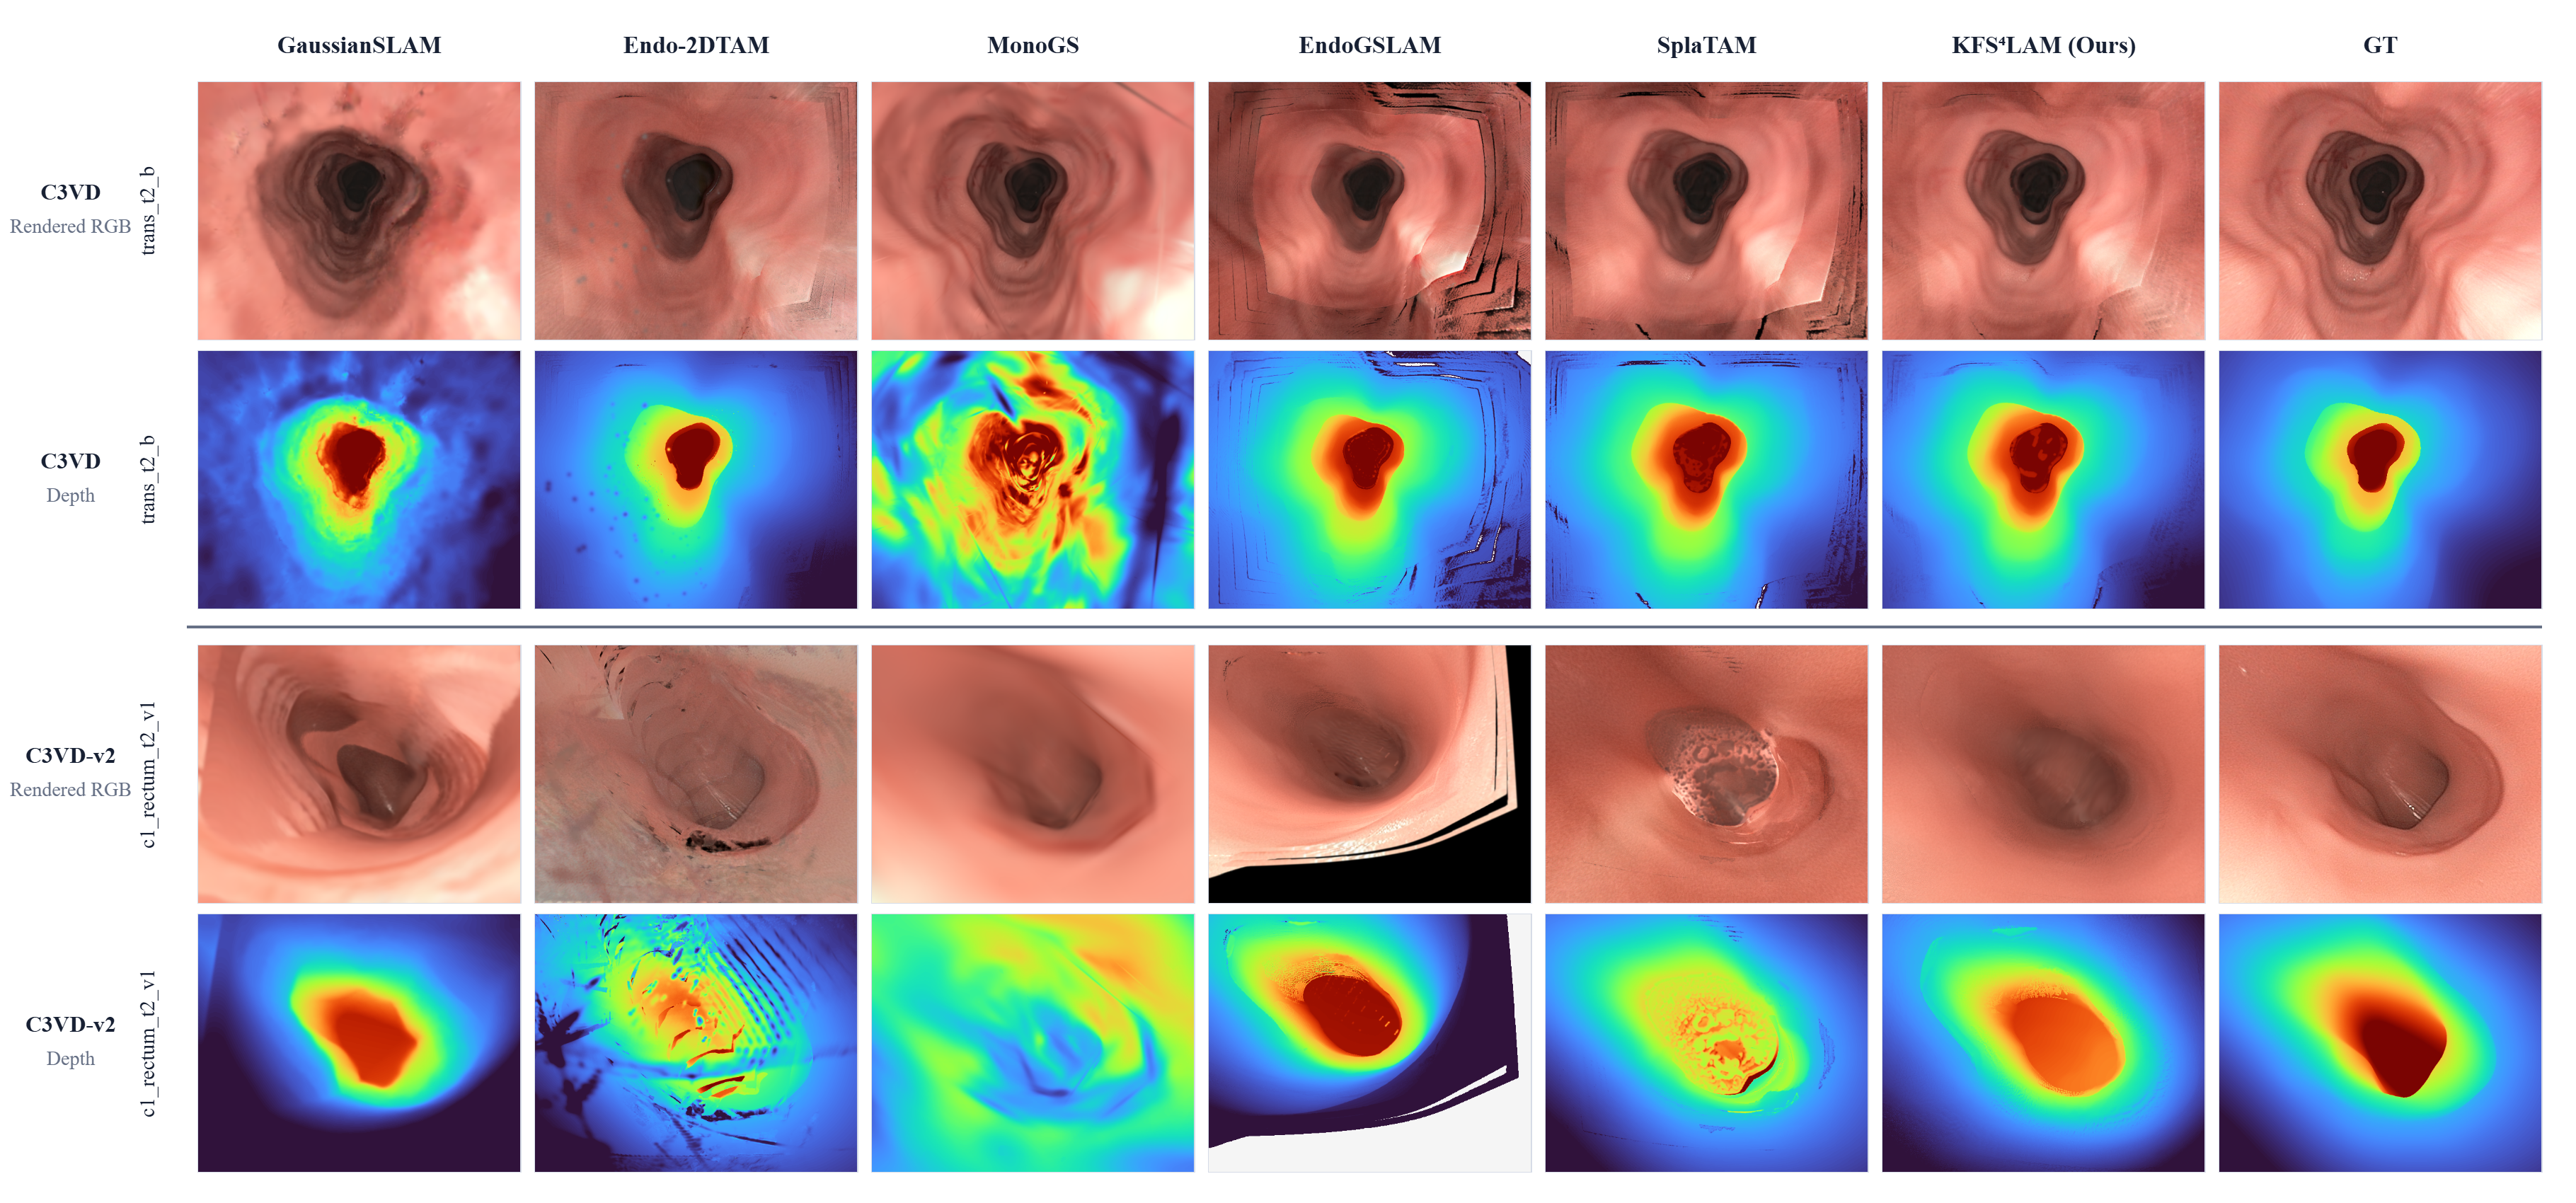
Quantitative Results
Common evaluation pool: 14 C3VD and 11 C3VD-v2 sequences. Trajectory and rendering protocols remain backbone-specific; depth values retain each source evaluator’s scale.
| Method | m ATE ↓ | m ARE ↓ | RPE-t ↓ | RPE-r ↓ | PSNR ↑ | SSIM ↑ | LPIPS ↓ | Depth RMSE ↓ |
|---|
Method
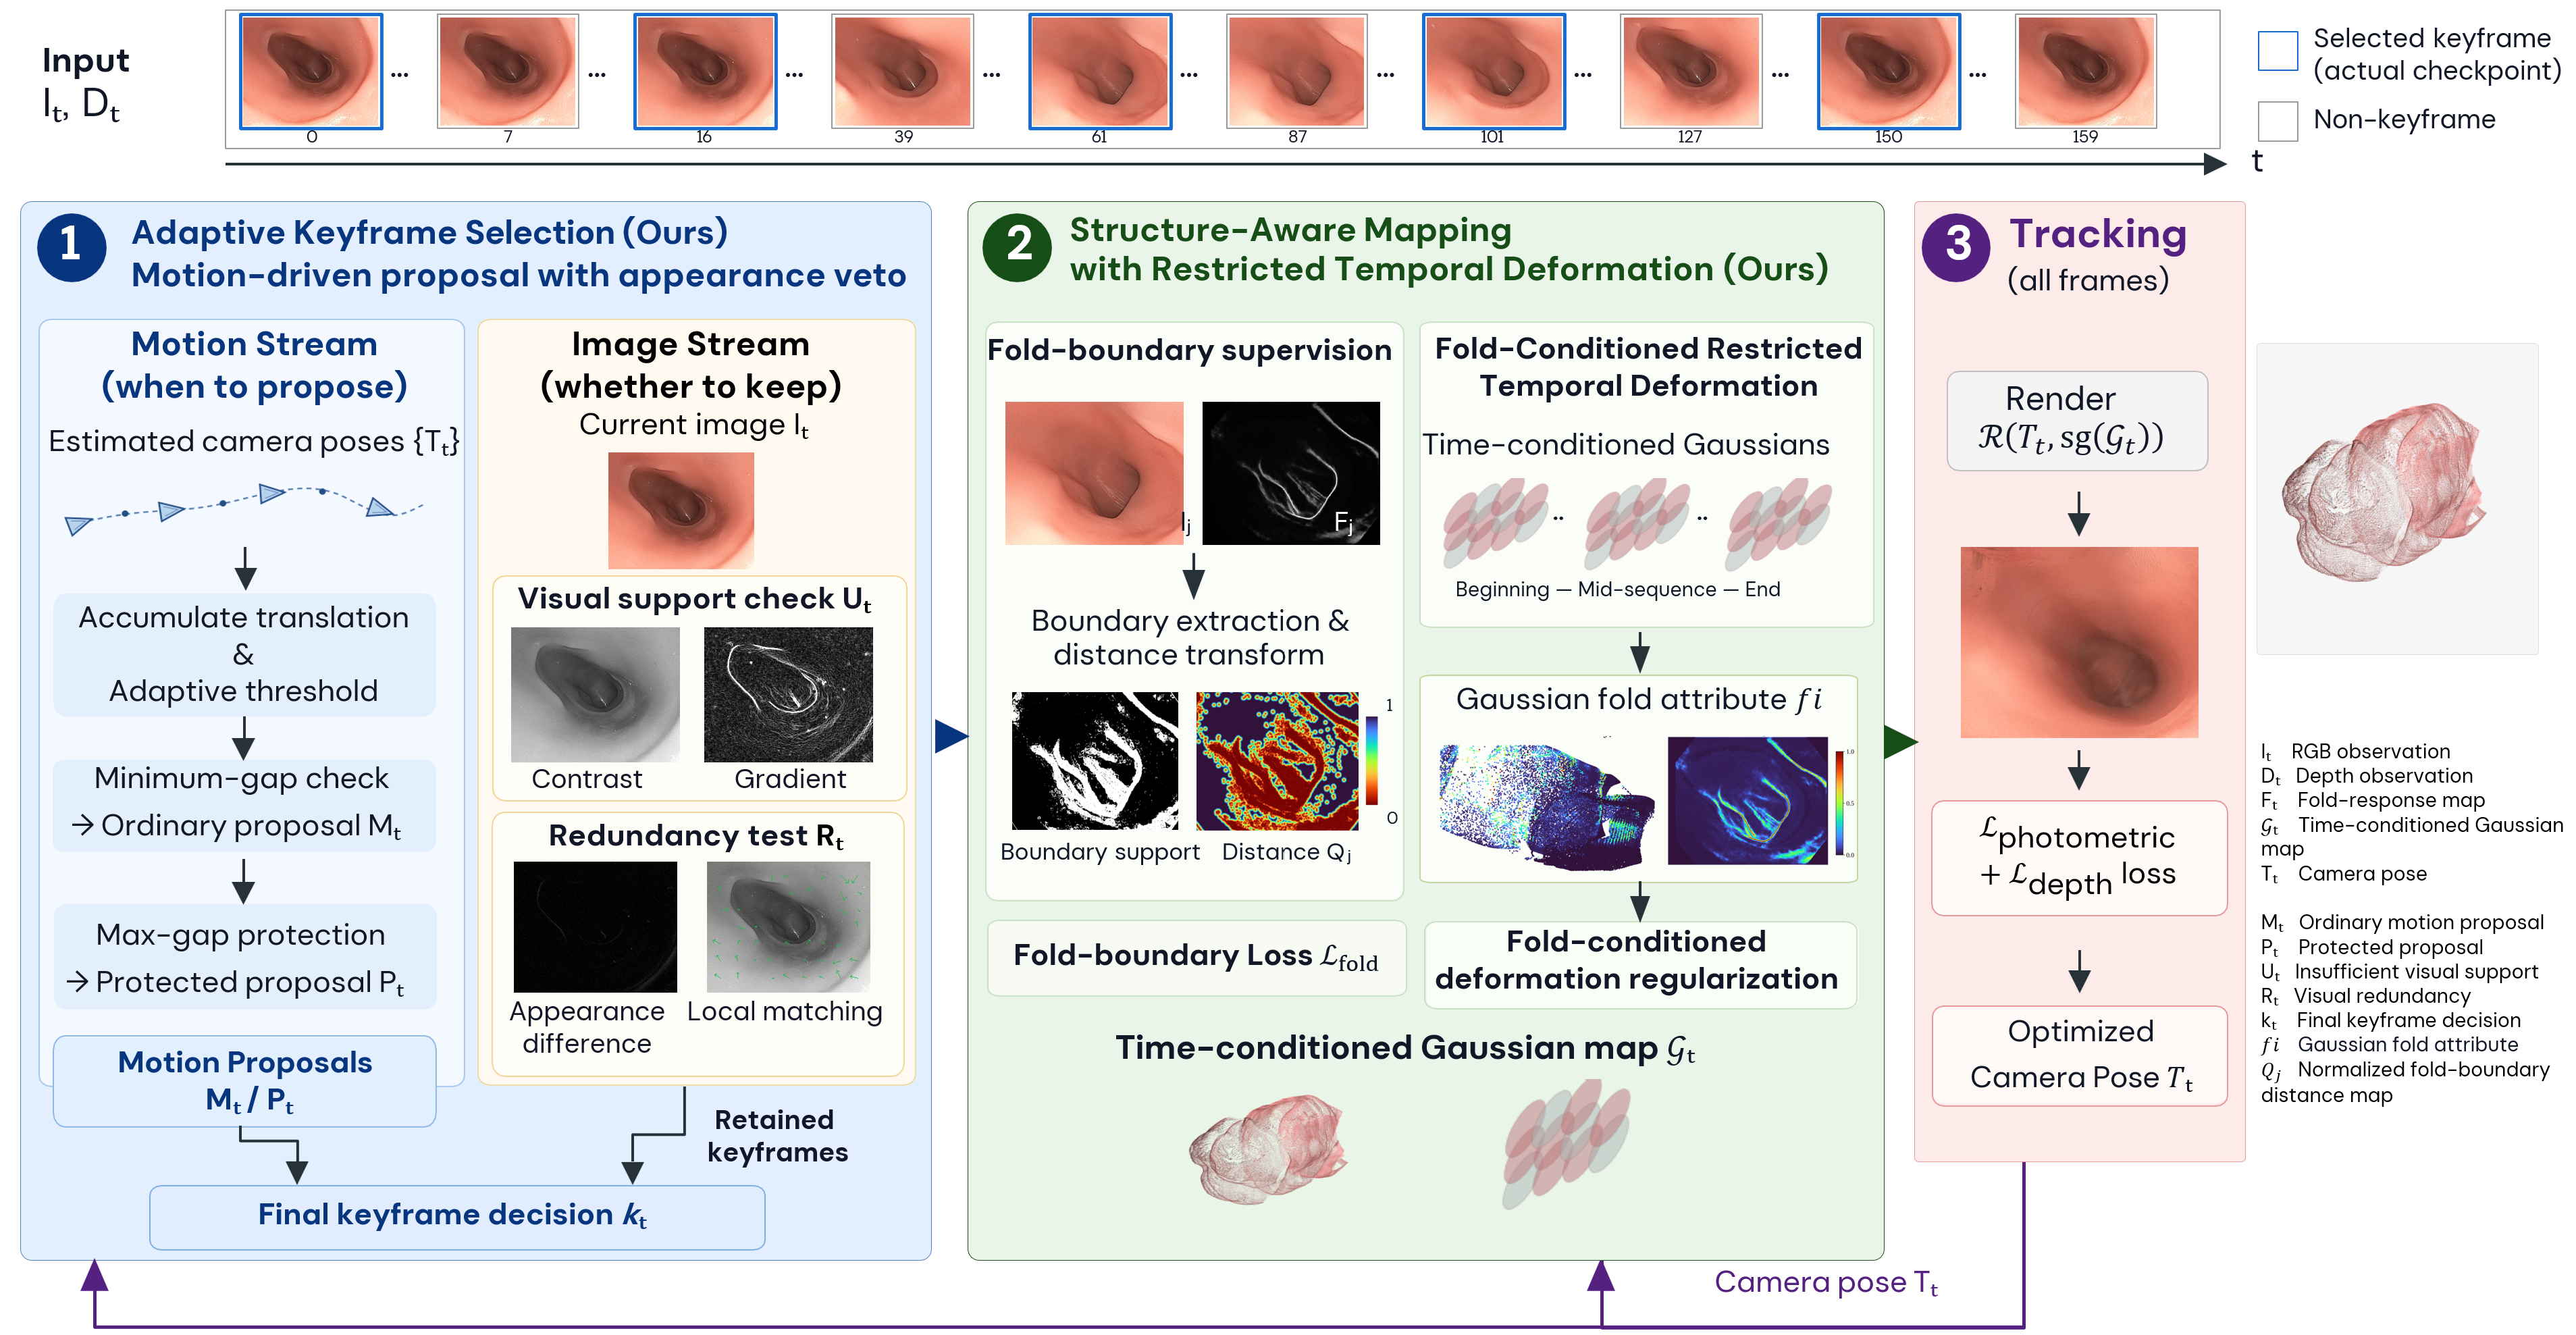
KFS⁴LAM combines motion-driven keyframe proposals, appearance-based redundancy suppression, fold-boundary supervision and restricted temporal deformation for Gaussian mapping.
Reproduce
Browse the code and installation instructions
The reconstruction collection comprises 25 KFS⁴LAM sequence archives. Each archive contains Gaussian parameters, estimated poses, intrinsics, keyframe indices and a portable configuration. The archives also contain temporal deformation coefficients. Rendering saved poses does not require retraining or the source dataset.
python render_checkpoint.py --backbone splatam \
  --checkpoint params.npz --frames all --stride 8 --output rendered
Install the code release dependencies first. RGB-D and fold responses are required for a new SLAM run; the original RGB-D dataset is required for evaluation against ground truth.
Checkpoints / Reconstruction Downloads · 25 sequence archives, per-sequence metadata and metrics.